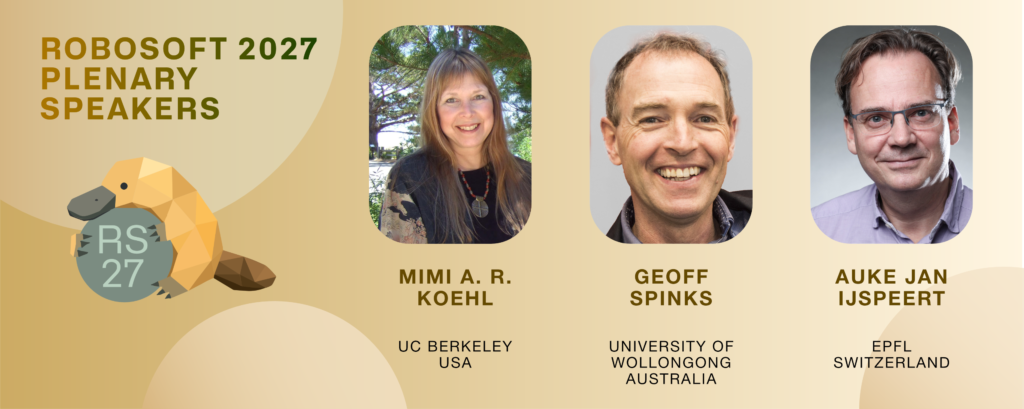
We are excited to announce our plenary speakers for RoboSoft 2027:
Mimi A. R. Koehl (UC Berkeley, USA)
Features affecting performance of biological hydrostatic and hydraulic systems
In her plenary talk, Professor Koehl will explore the biomechanics of hydrostatic skeletons, from frog embryos to burrowing worms and sea anemones, and show how their structure shapes movement and survival. Her findings offer design lessons for how soft robots can accomplish a variety of functions across different environments.
Geoff Spinks (University of Wollongong, Australia)
Soft Actuators and the Quest for Muscle-Like Materials
Professor Spinks will take us through nearly 30 years of progress on artificial muscles, from materials such as carbon nanotubes and hydrogels to applications like swimming fish robots and cardiac assist devices, and the challenges that have yet to be solved.
Auke Jan Ijspeert (EPFL, Switzerland)
Investigating the role of embodiment and distributed control in animals using robots and neuromechanical simulations
Professor Ijspeert will discuss the ways biorobotics and numerical models can be used to explore the underlying mechanisms behind animal locomotion, emphasising the importance of embodiment in the robustness and adaptation of both animal and robot locomotion.
Our plenary program shows how soft robotics draws strength from many disciplines: decoding the biomechanics of living organisms, pursuing muscle-like materials, and uncovering how the body itself shapes movement. Together, these talks offer complementary perspectives on where the field is heading.
For the full abstracts of the plenary talks, please visit:
https://robosoft27.com/plenary-speakers/